PneuGelSight: Soft Robotic Vision-Based Proprioception and Tactile Sensing
发表于 The International Journal of Robotics Research (IJRR),2025
Ruohan Zhang, Uksang Yoo, Yichen Li, Arpit Agarwal, Wenzhen Yuan
摘要
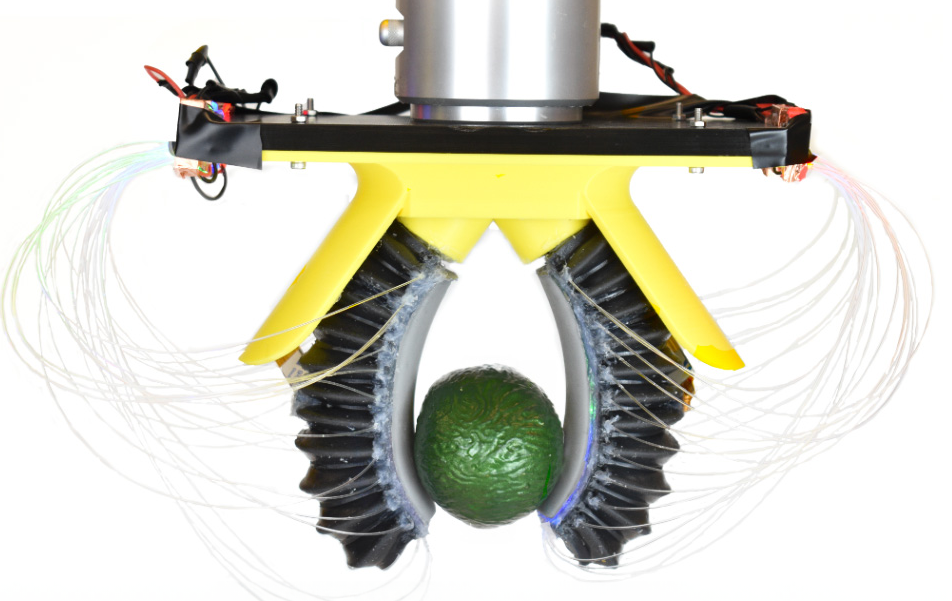
软体气动机器人操作臂凭借其柔顺性与灵活性,在工业和人机交互场景中得到广泛应用。然而,要将它们部署到真实场景中,需要先进的传感能力来提供触觉反馈与本体感知。本工作提出了一种新颖的、基于视觉的软体机器人传感方案,并在 PneuGelSight 上进行了验证——这是一款开创性的气动操作臂,通过内嵌相机实现高分辨率的本体感知与触觉传感。为优化传感器性能,我们提出了一套完整的仿真流程,能够准确模拟其光学与动力学特性,从而实现从仿真到真实世界的零样本知识迁移。PneuGelSight 及我们的 sim-to-real 流程为软体机器人提供了一种新颖、易于实现且鲁棒的传感方法,为发展感知能力更强的软体机器人铺平了道路。
引用
@article{zhang2025pneugelsight,
  title         = {PneuGelSight: Soft Robotic Vision-Based Proprioception and Tactile Sensing},
  author        = {Zhang, Ruohan and Yoo, Uksang and Li, Yichen and Agarwal, Arpit and Yuan, Wenzhen},
  journal       = {The International Journal of Robotics Research},
  year          = {2025},
  eprint        = {2508.18443},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2508.18443}
}
推荐引用格式: Ruohan Zhang, Uksang Yoo, Yichen Li, Arpit Agarwal, Wenzhen Yuan. (2025). "PneuGelSight: Soft Robotic Vision-Based Proprioception and Tactile Sensing." The International Journal of Robotics Research (IJRR).
下载论文