学术论文

你也可以在我的谷歌学术主页上找到我的论文。

期刊论文


x

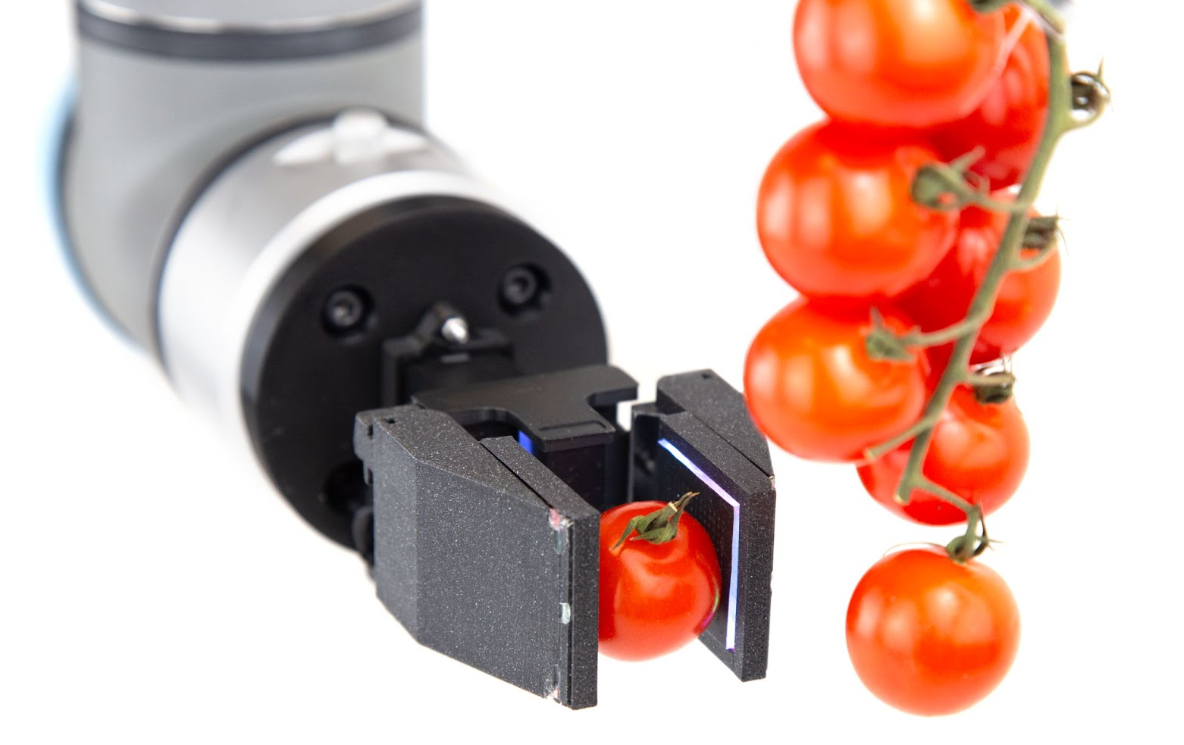
FruitTouch: A Perceptive Gripper for Gentle and Scalable Fruit Harvesting

发表于 IEEE Robotics and Automation Letters (RA-L),2026

我们提出 FruitTouch:一款集成高分辨率视觉触觉传感的紧凑夹爪,通过实时的力、滑动与软硬度估计,实现温和且可规模化的水果采摘。

Recommended citation: Ruohan Zhang, Mohammad Amin Mirzaee, Wenzhen Yuan. (2026). "FruitTouch: A Perceptive Gripper for Gentle and Scalable Fruit Harvesting." IEEE Robotics and Automation Letters (RA-L).
x

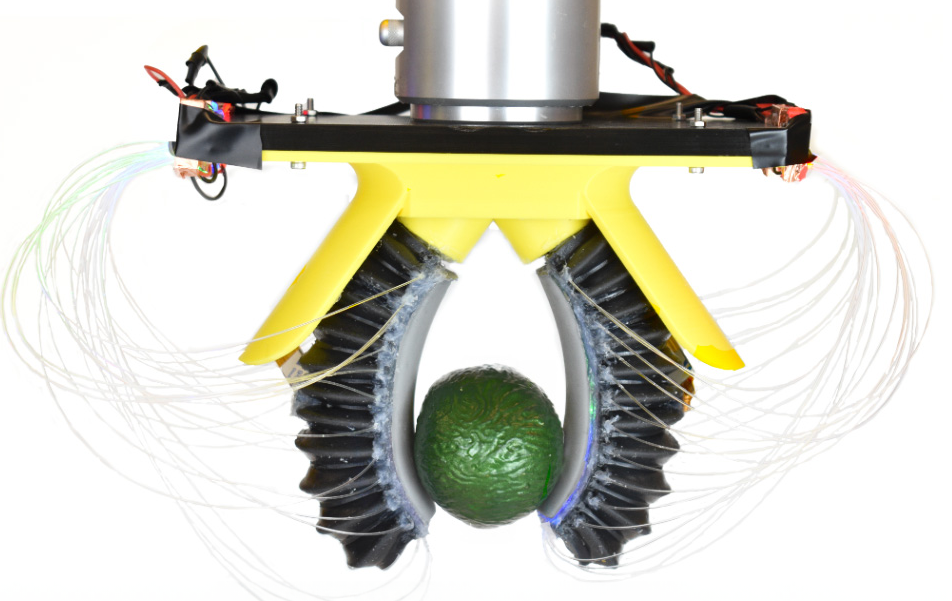
PneuGelSight: Soft Robotic Vision-Based Proprioception and Tactile Sensing

发表于 The International Journal of Robotics Research (IJRR),2025

我们提出 PneuGelSight:一款集成视觉触觉传感与本体感知的气动操作臂。我们的流程可精确模拟其光学与动力学特性,支持零样本 sim-to-real 迁移,实现稳健的操作。

Recommended citation: Ruohan Zhang, Uksang Yoo, Yichen Li, Arpit Agarwal, Wenzhen Yuan. (2025). "PneuGelSight: Soft Robotic Vision-Based Proprioception and Tactile Sensing." The International Journal of Robotics Research (IJRR).
Download Paper

会议论文


x

Requirement-Driven Design of Whole-Body Social Tactile Sensing via Virtual Human-Robot Interaction

发表于 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS),2026

我们提出一种需求驱动的框架,直接从 VR 采集的人机交互数据中推导全身触觉传感需求——空间分辨率与布置位置,并发布了包含 5,520 次社交触摸试验的开源数据集。

Recommended citation: Dakarai Crowder, Ruohan Zhang, Alexis E. Block, Wenzhen Yuan. (2026). "Requirement-Driven Design of Whole-Body Social Tactile Sensing via Virtual Human-Robot Interaction." IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS).
Download Paper